Sensor Alternatives to the TSL262

The TSL262 sensor has been popular with a number of micromouse builders. It is compact, easy to use and results in a low component count. A common alternative is the use of a simple phototransistor in an emitter foloower configuration. So, why change what works… (more…)
Continue ReadingSensor Alternatives to the TSL262

Making the floor

Now that I had the layout, the next step was to cut and drill the plywood.

While there are many techniques for doing this, I ended up getting help from a friend who has access to water jet cutters to do this.


(more…)

Continue ReadingMaking the floor

Designing a maze floor

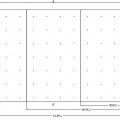
Given standard sizes for plywood, here is a pattern I used to make a maze floor. (more…)

Continue ReadingDesigning a maze floor

Robotic 2011

The annual winter micromouse contest was held at Millenium Point in Birmingham by the University of Central England on Saturday November 19th 2011. Unfortunately, I was not able to attend this year but I gather everyone had a great day. I have managed to gather some results and the finals maze though…

(more…)

Continue ReadingRobotic 2011

How many walls do you need for a square maze?

At the Japanese contest, Peter said there is a closed form solution for the maximum number of walls a legal micromouse maze can have. (more…)

Continue ReadingHow many walls do you need for a square maze?

All Japan Micromouse 2011 – results

A comprehensive set of results for the 2011 All Japan Micromouse Contest is now available from the NTF web site. You can find the maze layouts, prizes and results tables for all the events that were run. (more…)

Continue ReadingAll Japan Micromouse 2011 – results

All Japan Micromouse 2011 – finals

All the preparation and practice was over. The qualifiers had been held and the wheat sorted from the chaff. Now it was time to see who had what it takes to be the champion – the builder of possibly the fastest robots on the planet… (more…)

Continue ReadingAll Japan Micromouse 2011 – finals

All Japan Micromouse 2011 – Qualifying Day

The All Japan micromouse contest attracts a large number of participants. This year, the expert class has an entry list of 84 and there are 99 entries in the freshman class. With so many mice to run, Saturday is needed to thin the field and select the best contestants for the finals on Sunday…. (more…)

Continue ReadingAll Japan Micromouse 2011 – Qualifying Day

Taiwan 2011 micromouse contest videos

The Taiwan 2011 Micromouse and intelligent Robots Contest was a great success. Our primary contest organiser Juing-Huei Su has evidently been busy with the vido editing software as he has now uploaded the contest videos… (more…)

Continue ReadingTaiwan 2011 micromouse contest videos

Measure angular error using front sensors

The front, or forward-facing, sensors on a micromouse have several uses. Apart from detecting the distance to walls ahead and obstacles on one side or another, properly setup forward sensors can be used to measure an angular error with respect to a wall ahead of the mouse… (more…)

Continue ReadingMeasure angular error using front sensors